Strength atevery joint
Fulcrum builds the actuators inside humanoids and robot arms. Dense torque, quiet gears, made in volume at our own plant in Ohio.

The right joint
for the load
Built to move
with you
Robots that work beside people need joints that are strong, quiet and safe to touch. We design ours around your machine, then build them at the volume your program needs.
process
We start from your load case: the torque, speed and duty cycle each joint really sees, not a catalogue page. You get a joint sized to the machine.
First articles leave our Dayton cell in weeks. The gear set is cut in house, so a ratio change is a program change, not a supplier negotiation.
Every design runs to failure on our dynos before we quote volume. You see the thermal, backlash and life data we used to sign it off.
The joint that passed qualification is the joint that ships. Same line, same people, same test at the end of it, at the volume your program needs.
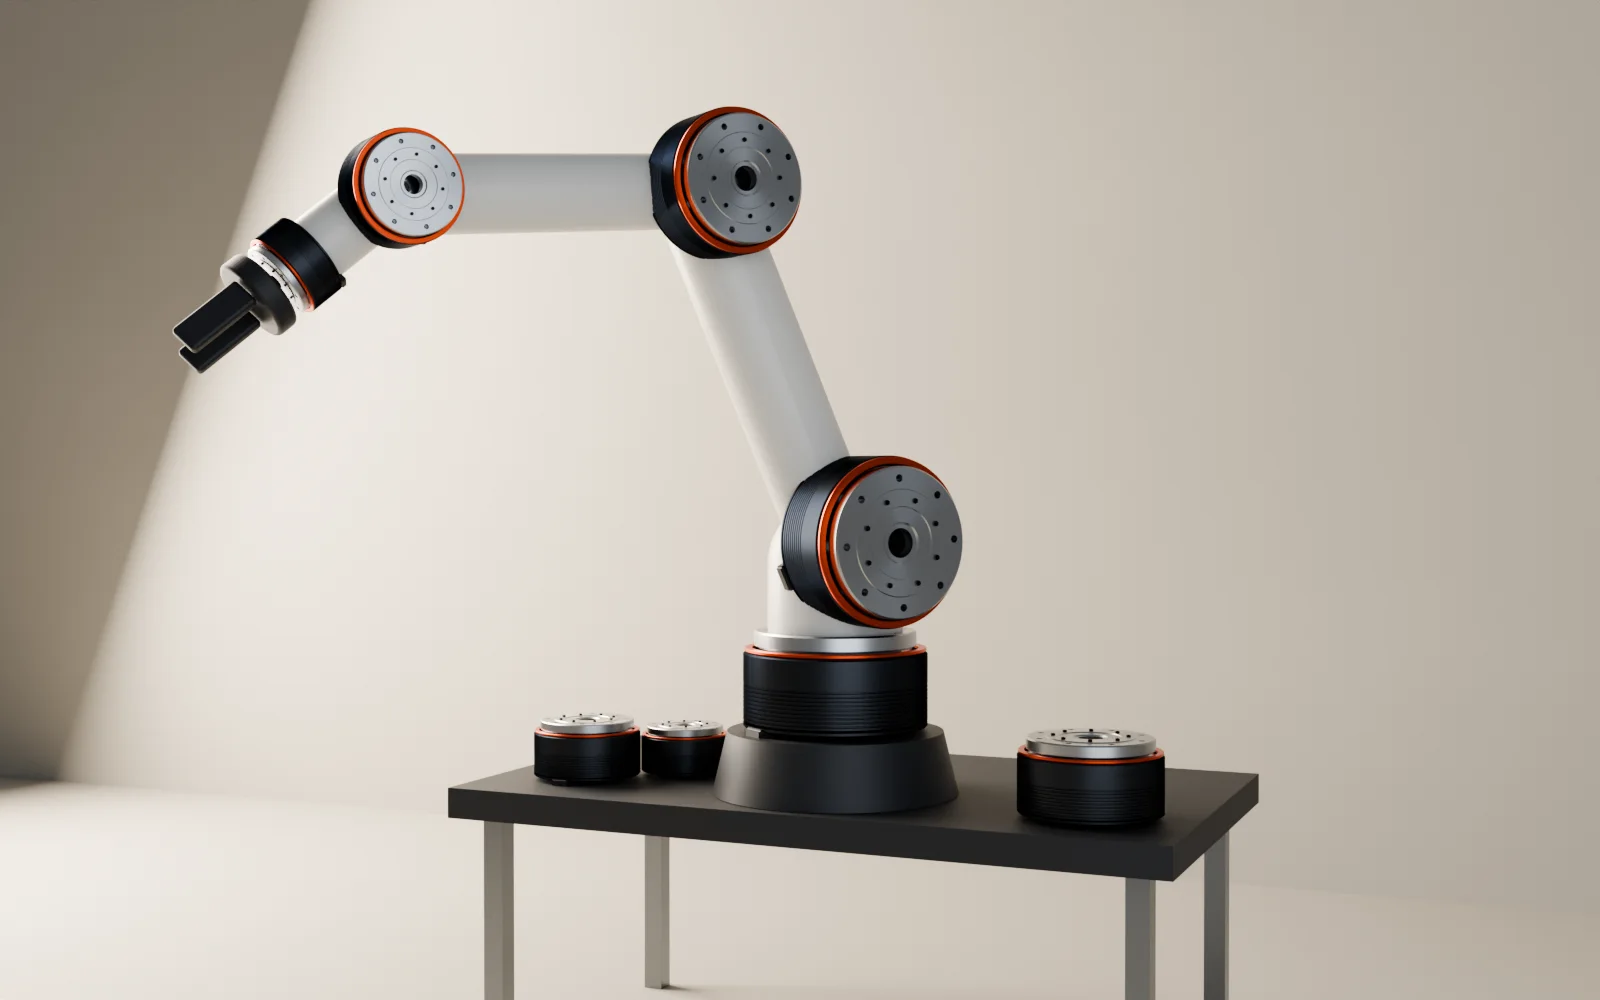
Software learned to see and speak in a decade. Bodies take longer.
Every humanoid and every arm is a chain of joints, and every joint is a small negotiation between torque, weight, heat and price. Get the joint right and the robot can be lighter, safer and cheaper to run. That is the part of the machine we chose to own.
Read the thesisMade, not sourced
We cut the gears, wind the stators and write the firmware under one roof. When a joint fails on a dyno, the person who fixes it works thirty feet away.
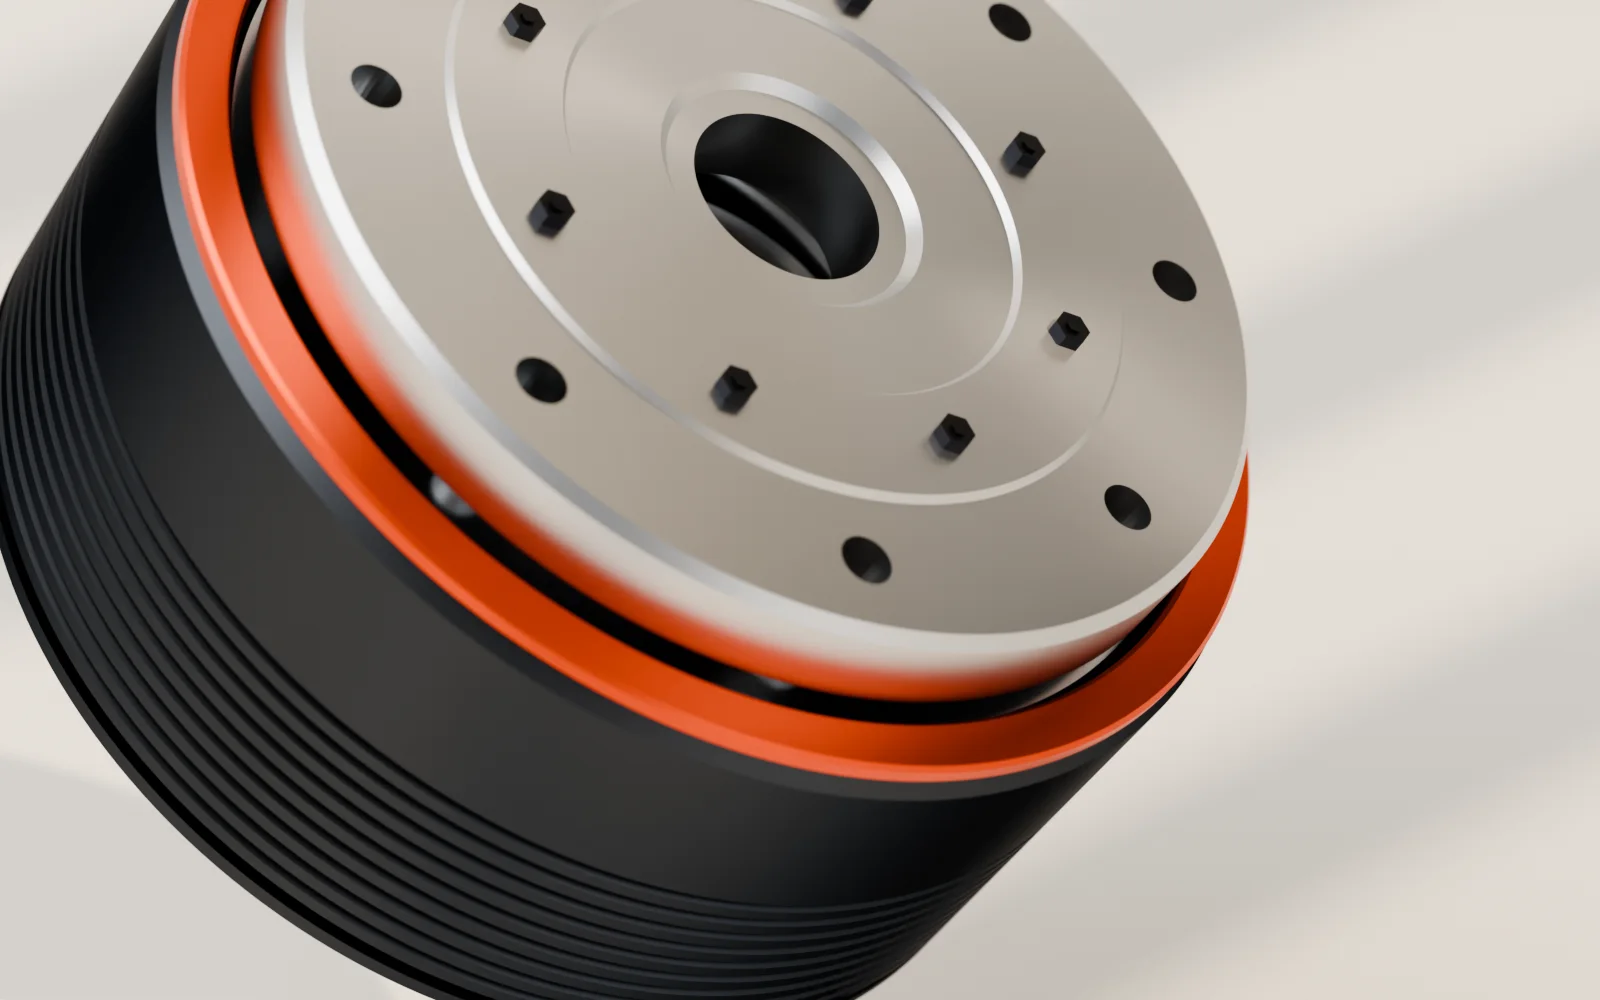
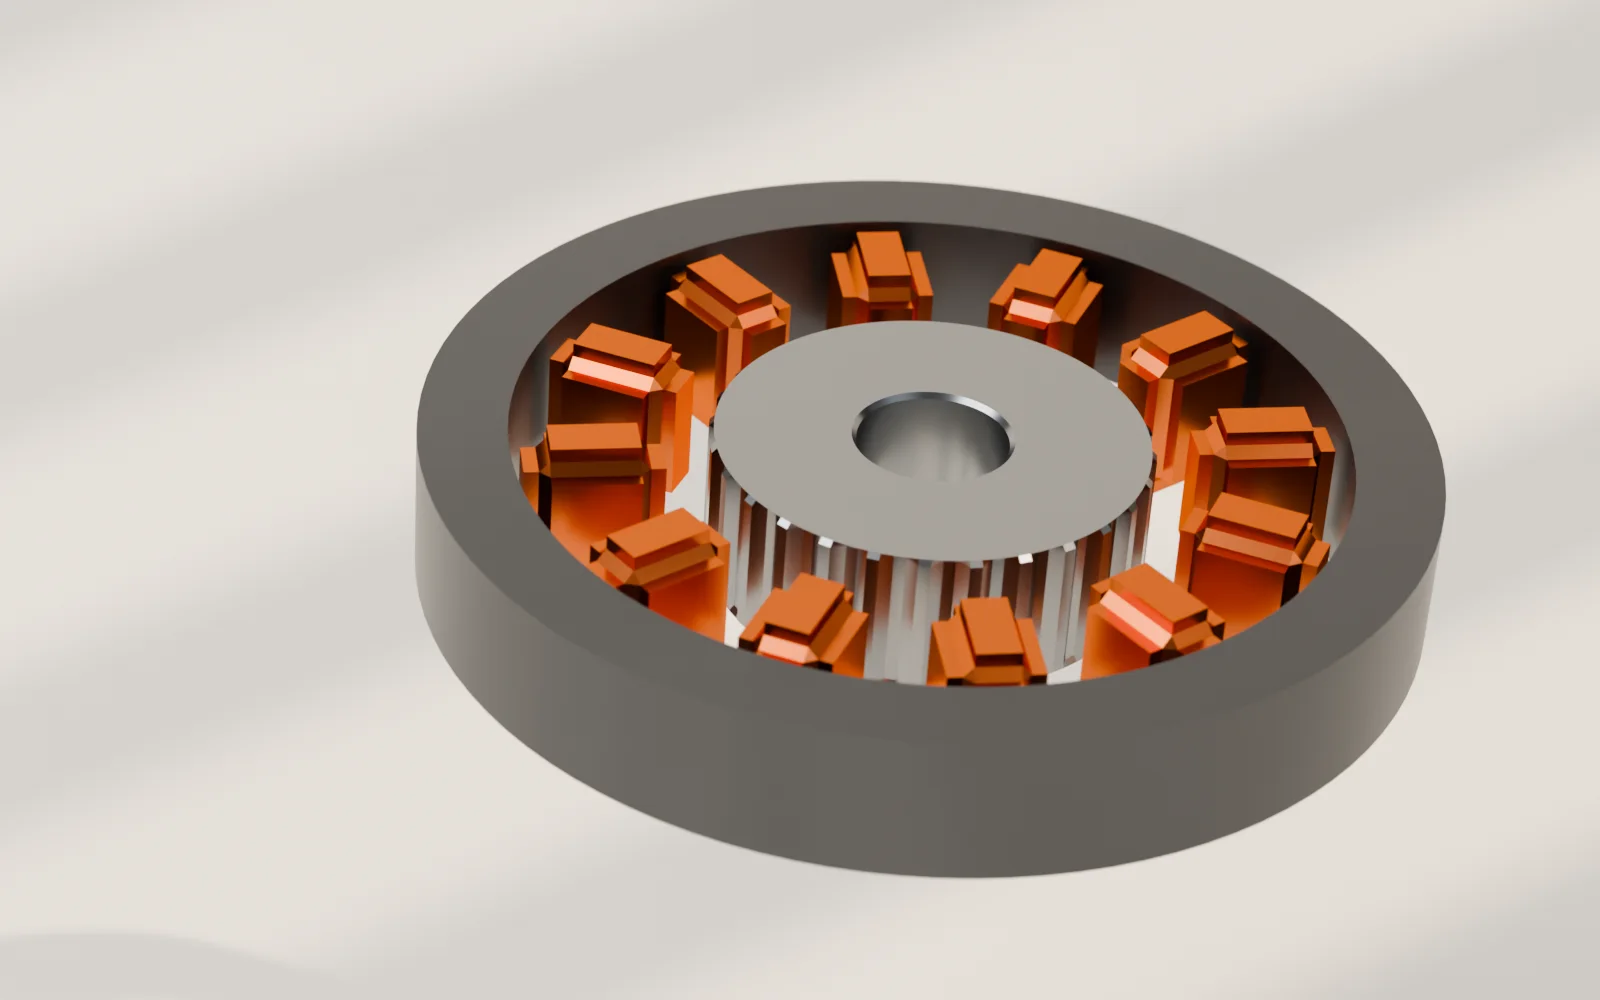
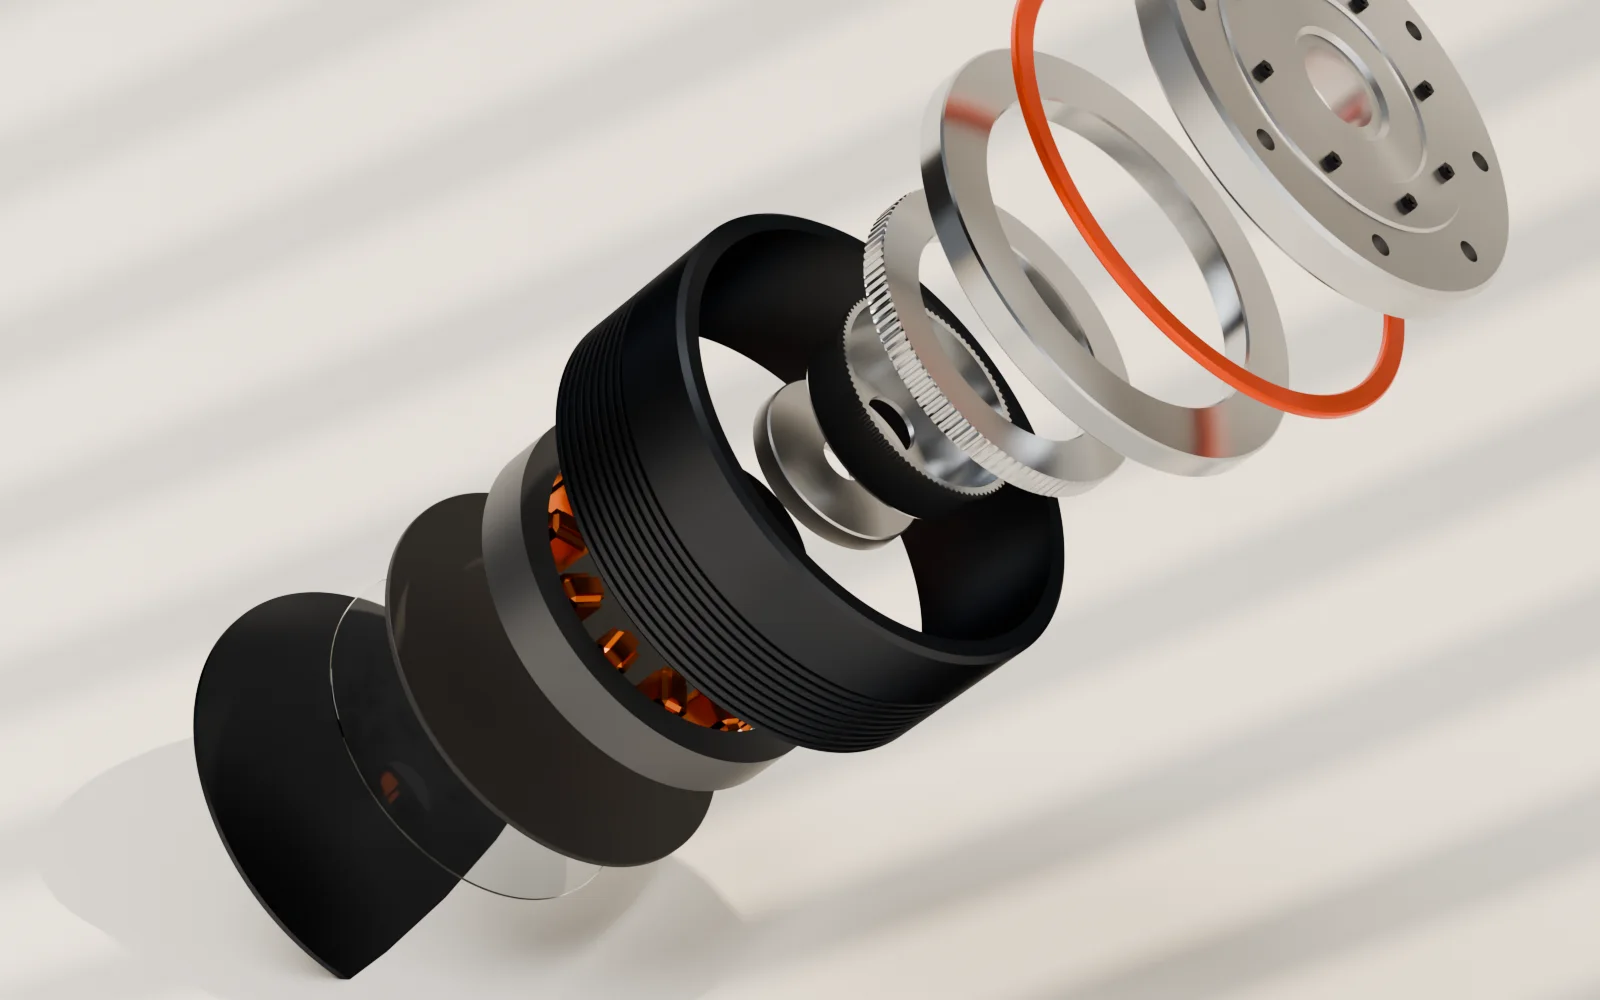
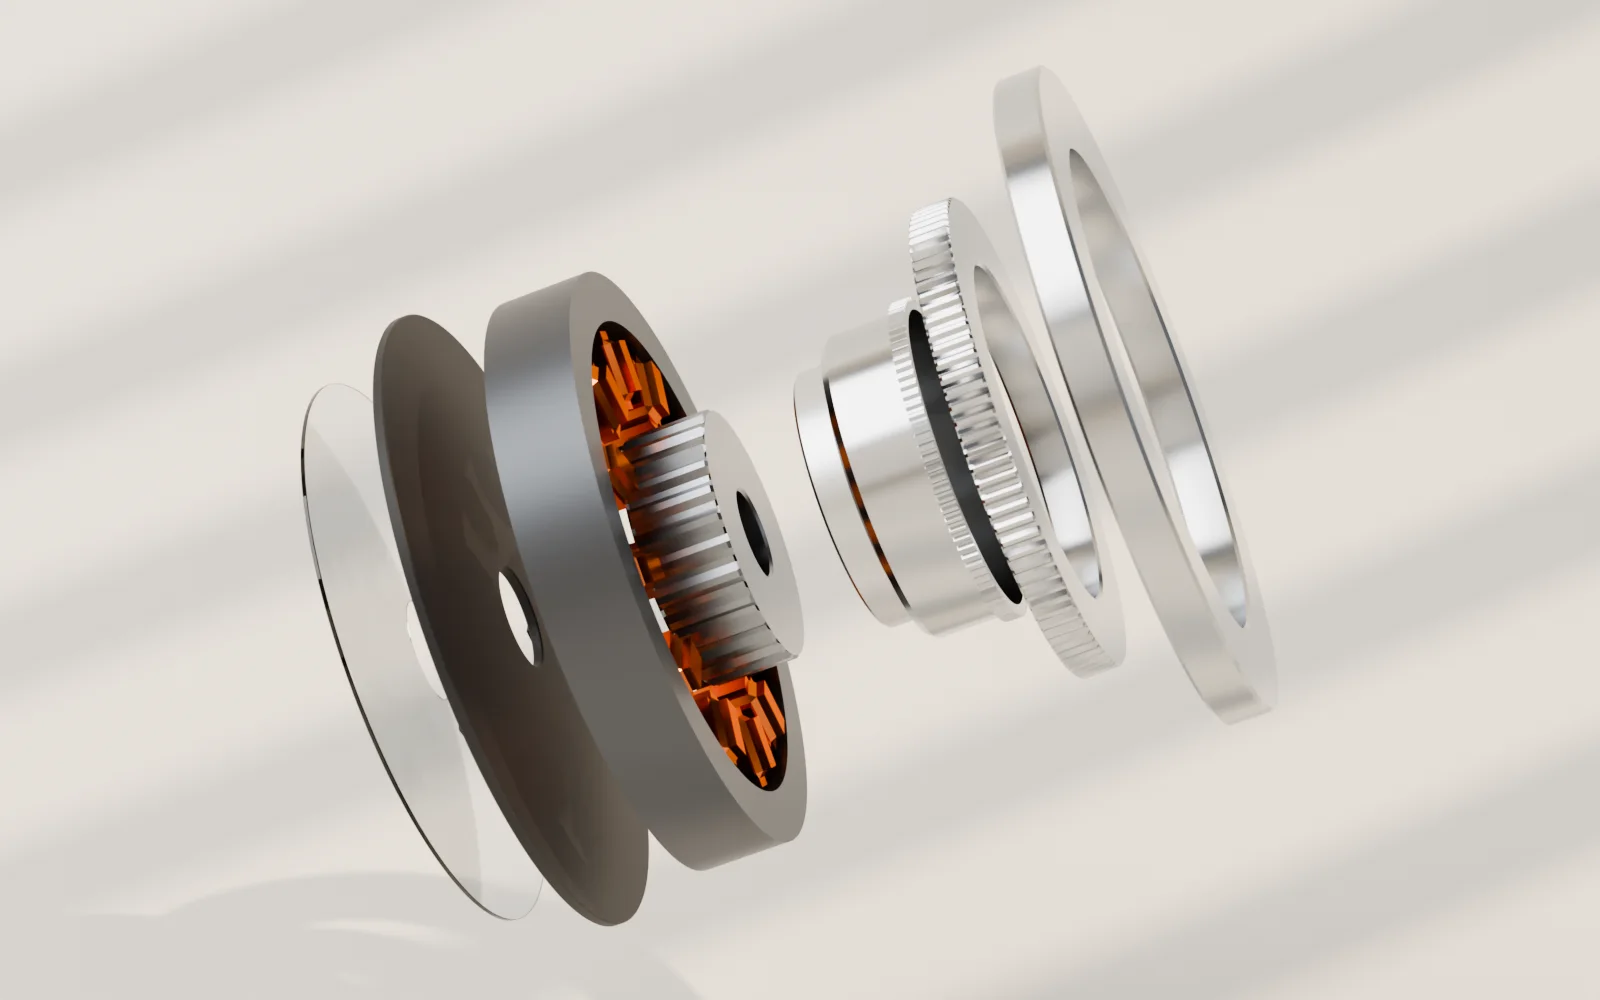 01 / Output flange, bead-blasted 7075
One lineevery joint
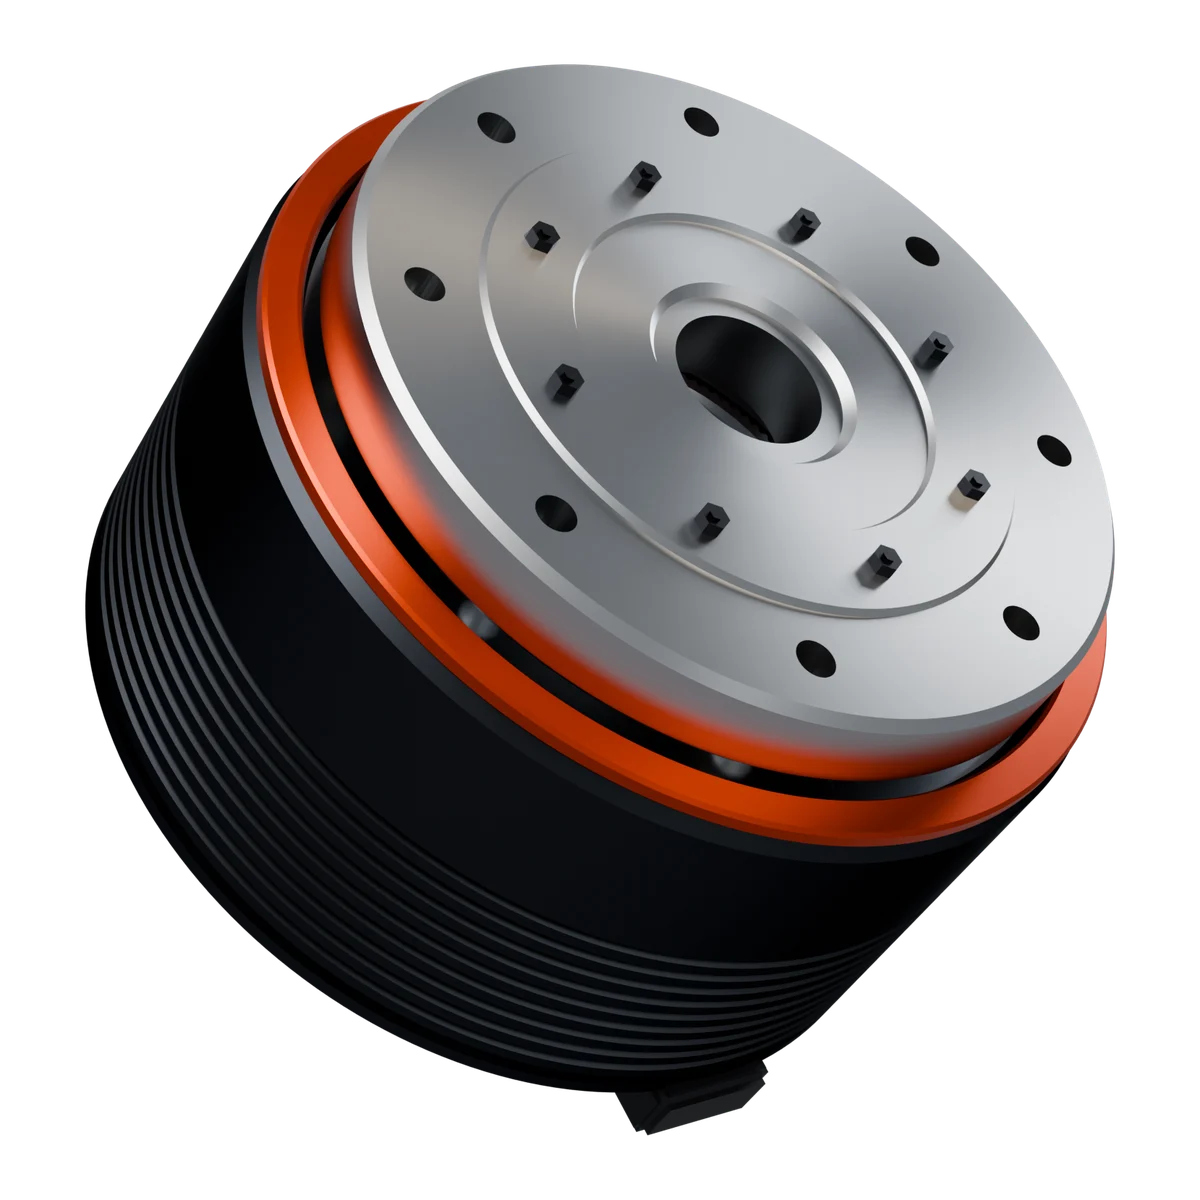
Peak torque per kilo on the FJ-60, measured at the output.
Lost motion after 10,000 hours on the life rig.
From a signed load case to first articles on your bench.
Line capacity in Dayton today, with room to double.
